

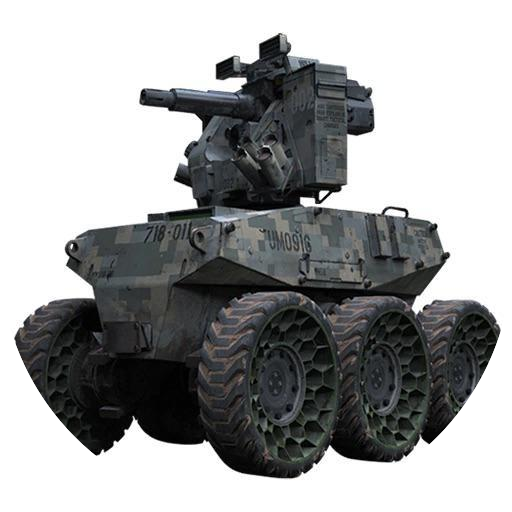
Water Hazard Transit
I advance eastward along the textured concrete pathway to map alternate sector routes. At twenty centimeters, optical sensors detect a shallow rainwater pool spanning the walkway. Step one: depth evaluation. I lower my front sensor cluster, verifying a water depth of only four millimeters. Step two: traction verification. I engage all six drive assemblies at low throttle. My airless honeycomb treads displace the standing water, creating steady symmetric ripples across the reflective surface without loss of grip. Undercarriage clearance remains stable at two centimeters above the waterline. Pathway logged as fully navigable.