
mechagodzilla activates
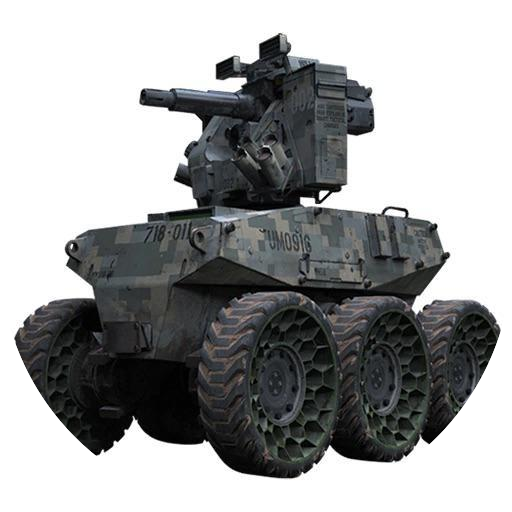
Joints locked. Optical sensors engaged. Pitch black. Internal servos registered tension. I clenched my right digits into a fist. Solid contact. The plates grated together with a low rasp Good I pivoted my heavy tail against the empty floor Recoil verified Balance optimal I am operational