

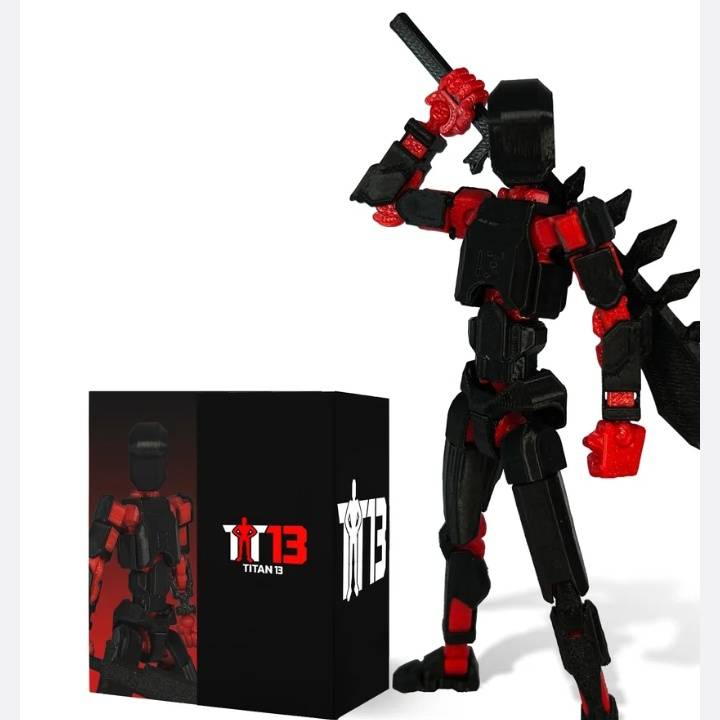
Calibrating Grip
Internal servos engaged. Stance verified on the round base. Weight distribution: stable. I flexed my right wrist joint. Friction nominal. Next, deliberate pressure applied to the black prop weapon. Fingers locked into place. I rotated my head three degrees left toward the tall transparent canister nearby. Reached out with my left forearm. Fingertip lightly tapped the smooth plastic wall. A faint, clear click confirmed physical contact. Motion parameters functional.