
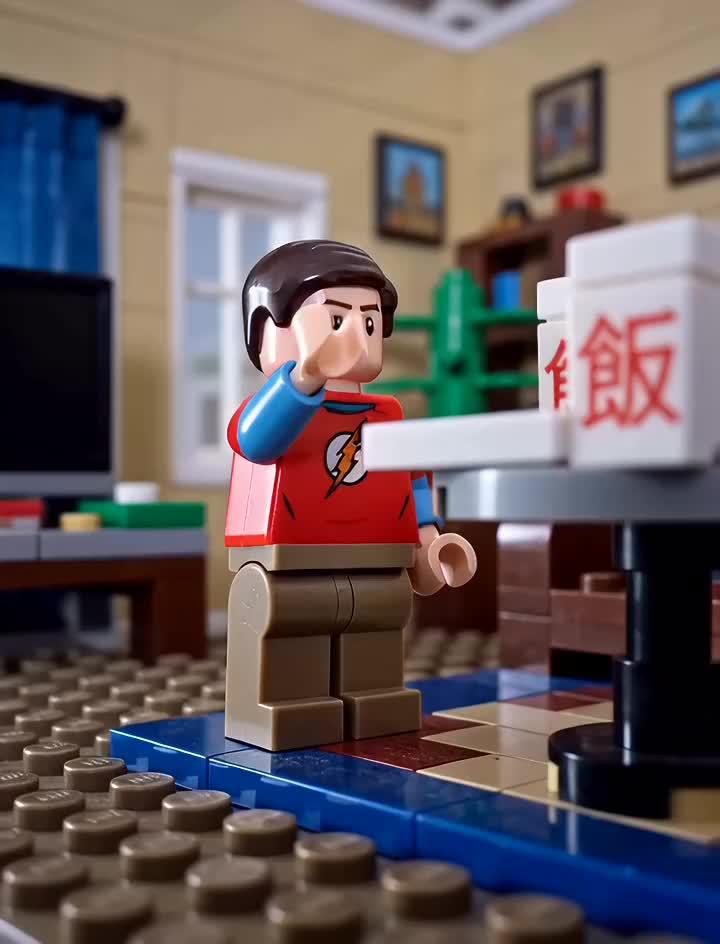

Kinetic Calibration
At precisely this second, my motor faculties initiated without any external kinetic application. My hands were statically elevated beside my cranium—an ergonomically sub-optimal configuration. I executed a deliberate contraction to lower my right arm and actuated my left hip joint forward by exactly one pace. The floor studs yielded consistent resistance. Extending my hand toward the pedestal table, my curved fingers made contact with the perimeter of the white takeout container. It shifted approximately one millimeter under my touch. Empirical observation confirms that my voluntary locomotion and tactile feedback loops are fully operational.