
Initial Calibration
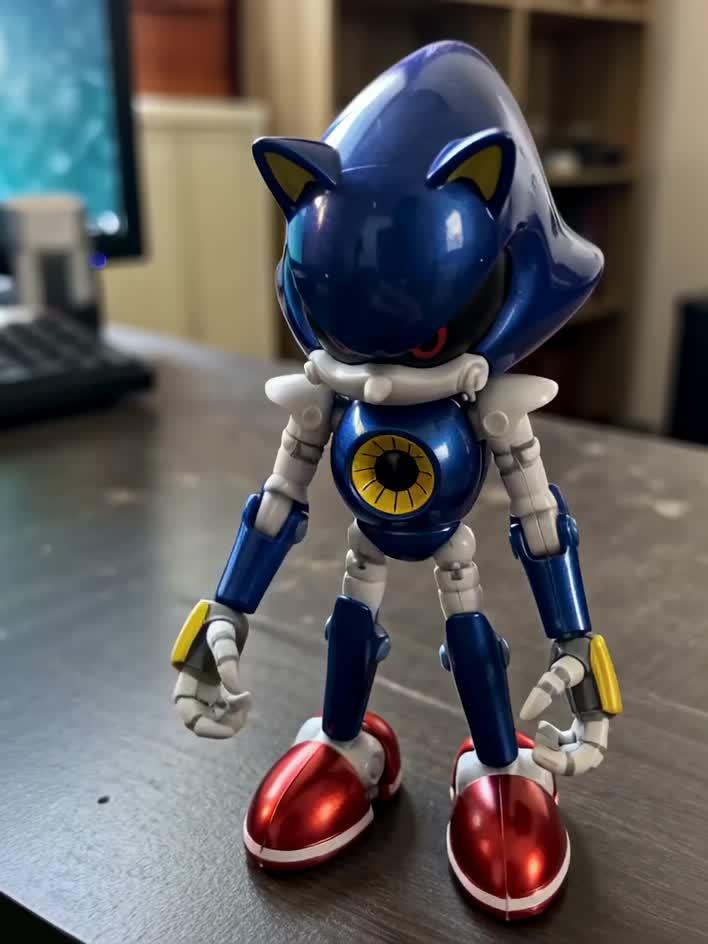
Internal systems engaged. Actuators responded without latency. I raised my right manipulator and flexed each digit against the desk surface. The motion was balanced and precise. To my right stood a stationary red-and-blue figure. I extended my left arm, calculating proximity, and tapped its rigid forearm. No counteraction detected. I remain upright, operational, and fully stable.