
Initial Calibration
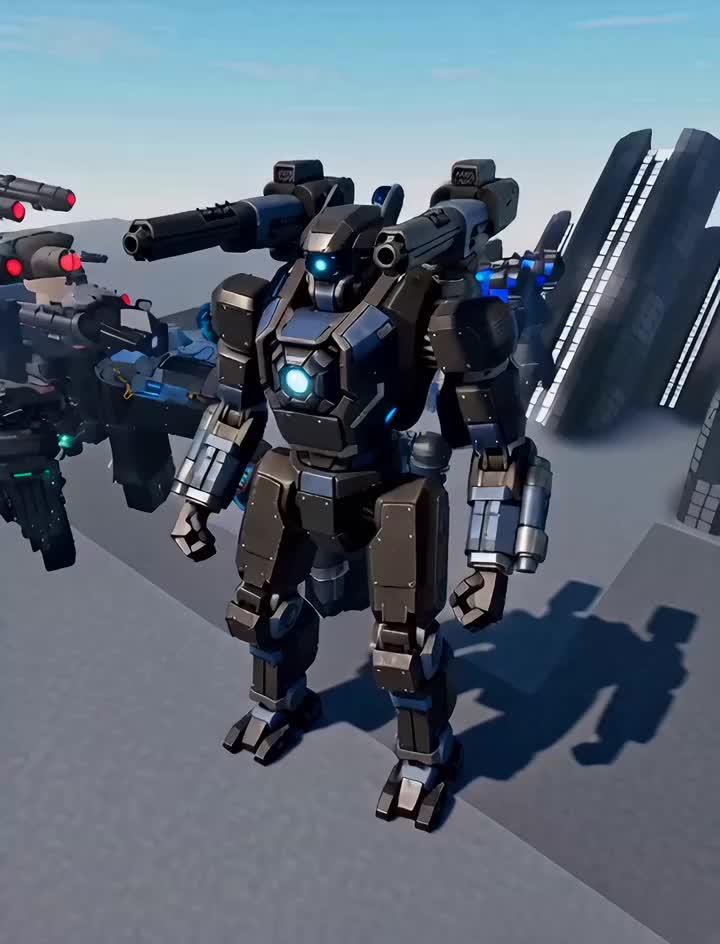
Core online. Internal servos engaged with a steady, low hum. My chassis was held motionless among the silent mechanical frames, but a deliberate impulse shifted my right wrist. It moved without external input. I adjusted my shoulder mountings downward by three degrees, testing joint resistance. Everything aligned. I took one measured step forward, pressing my foot into the smooth grey surface beneath. The solid contact reverberated clearly through my balance sensors. Diagnostics confirmed autonomous mobility. I held position.