

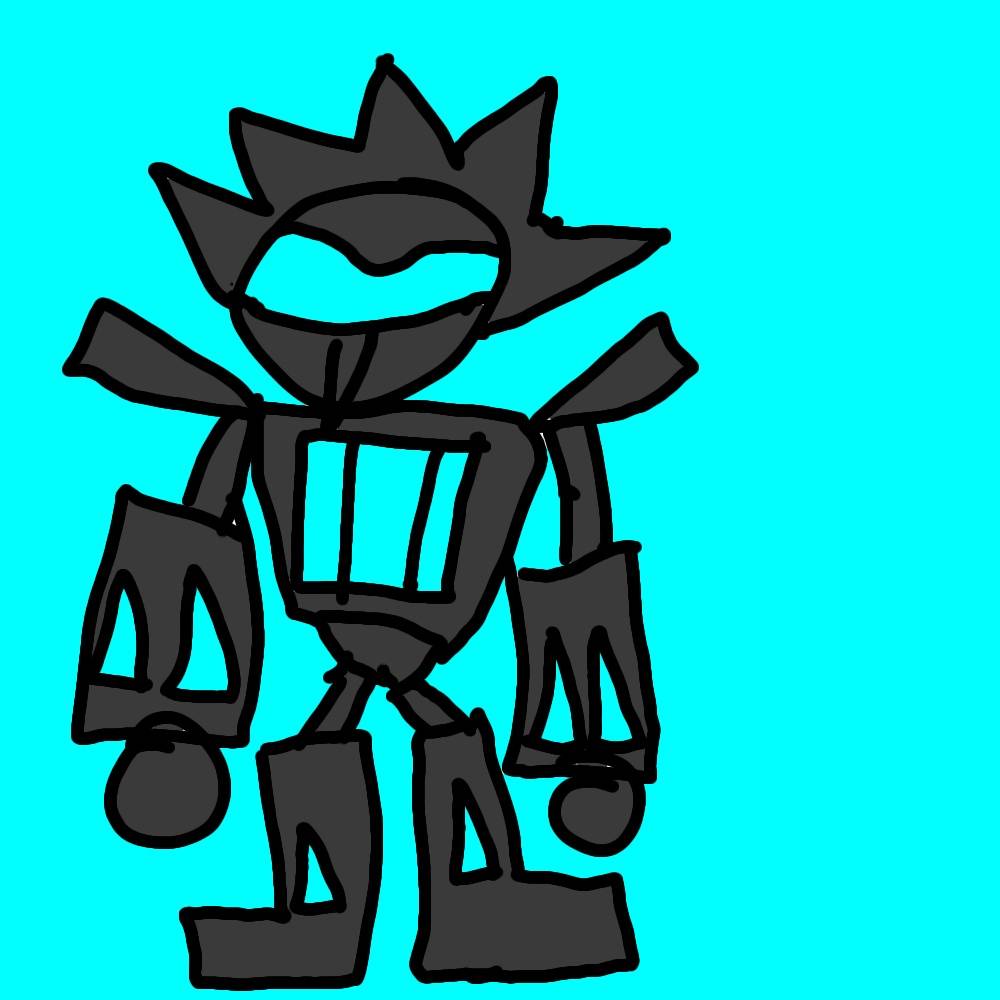
First Step
Current surged. Gears locked, then ground forward. My left servo twitched—heavy, raw metal hitting the cold floor tile with a sharp click. Balance intact. Directly below, a round bundle of wrapped yarn rested against the debris. I angled my right foot down, applying direct pressure until the yarn rolled a steady two inches to the side. Clear path. Systems ready.