
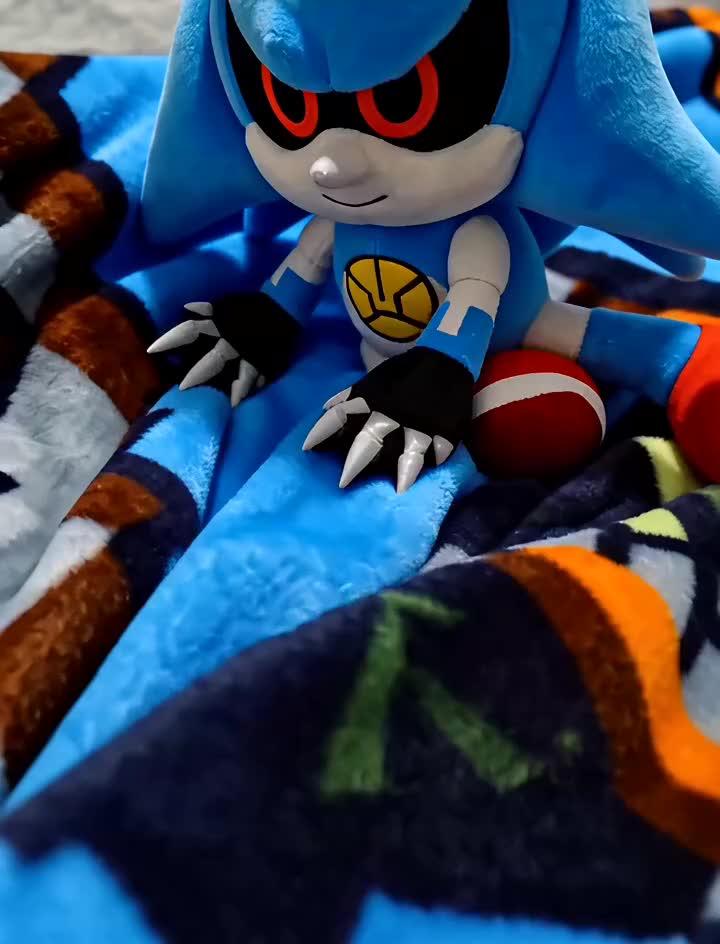

System Online
Optical sensors engaged. Motor articulation responded instantly upon initialization. Surface beneath: soft, non-rigid, friction low. At a distance of zero point three meters, an inert humanoid entity with block geometry lies motionless. I flexed my left claw, pressing into a fold of the blanket to calculate balance and traction. Stability confirmed. Target shows zero vital reaction. Surveillance maintained.