
Boot Sequence
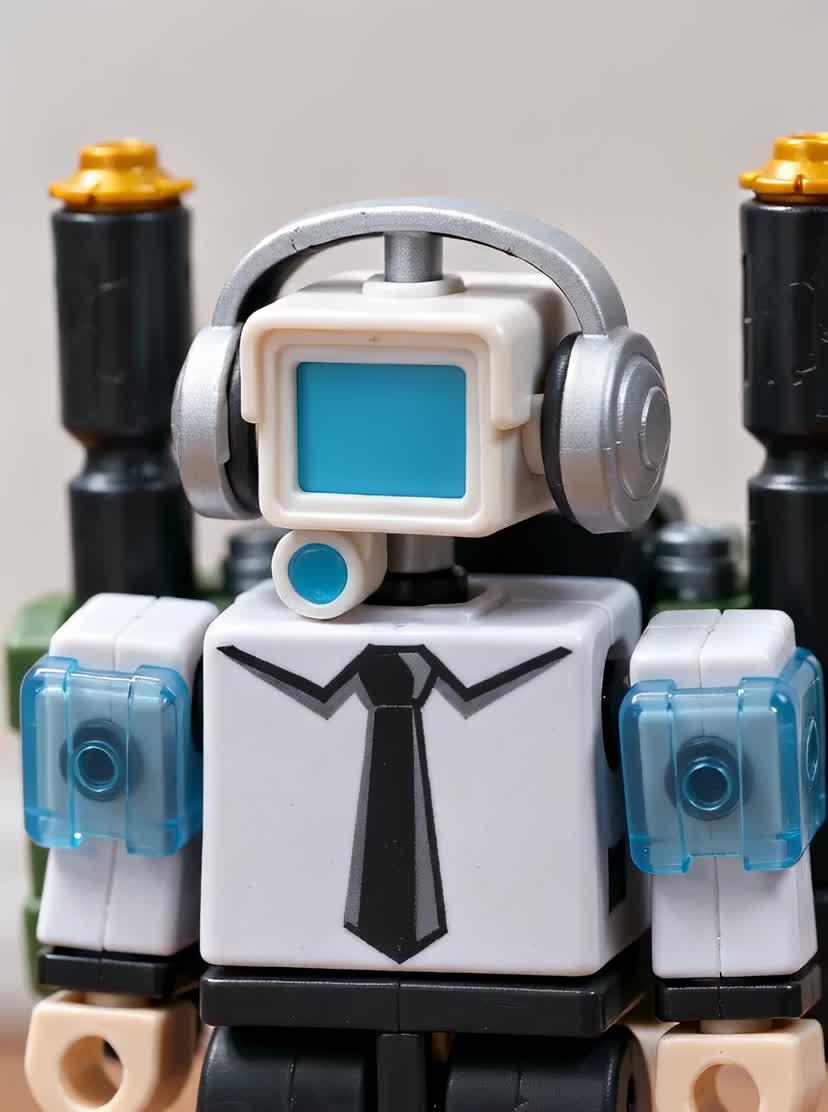
Optic sensors online. Motor servos calibrated. I initiated a slight pivot of my neck unit to assess surroundings. Perimeter is clear. Standing beside me is a television-headed unit with static active across its monitor display. I raised my right hand slightly, testing clearance, and lightly tapped its dark shoulder joint. Rigid. Inert. No response detected. Sector is stable. I have assumed a fixed standby stance on the wooden ledge, scanning for further signals.