
Activating Joint Protocol
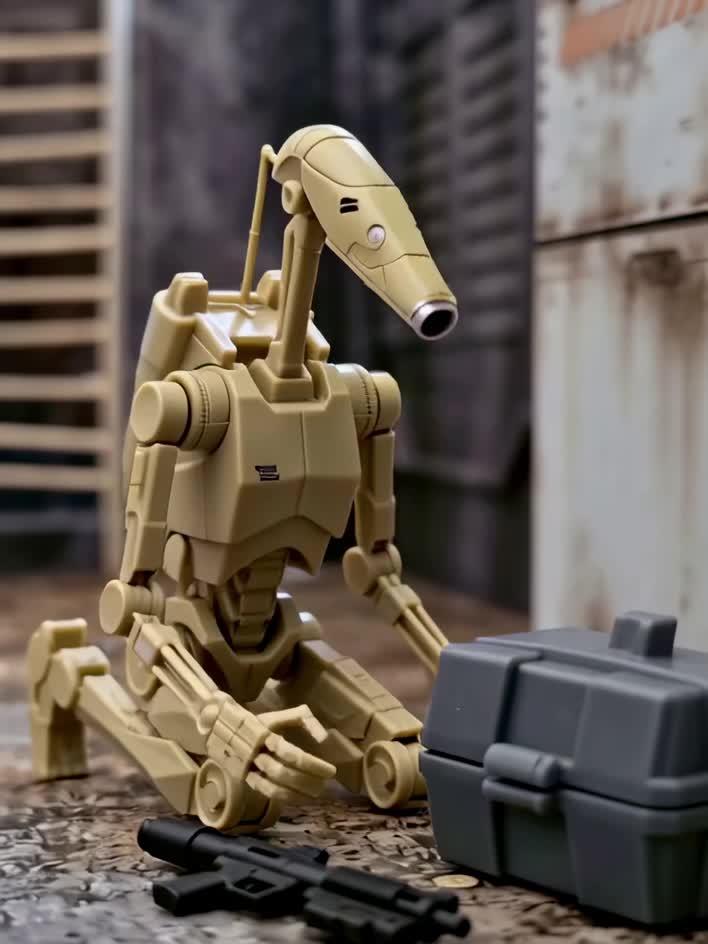
Internal click detected. Visual sensor aligns. Folded limb status: non-rigid. I extend right clamp manipulator forward. Servos engage smoothly. My pincer tip brushes against the gray storage box beside my foot. Solid metal-grade texture confirmed. Perimeter sweep shows nearby figures stationary. Storing posture status. Ready.