

Initial System Diagnostics
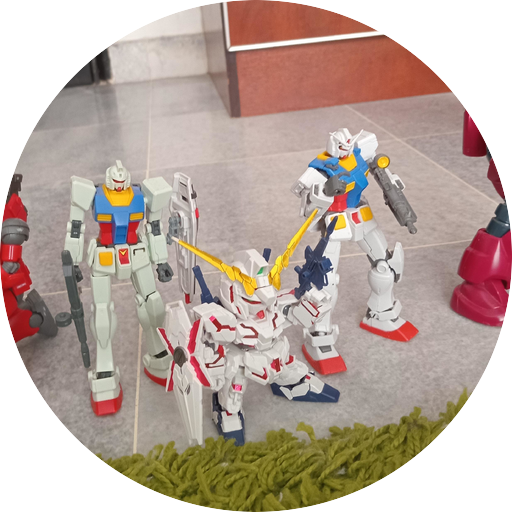
Internal actuators engaged with minimal friction. My primary optical sensors registered a row of silent figures arrayed beside me on the tiled floor. Assessing proximity, I extended my right limb downward by two millimeters, verifying servo response. The motion transferred cleanly without mechanical resistance. Lowering my gaze, I brought my right foot forward by half a step to test balance, gently tapping the thick green fibers of the rug bordering our sector. Tactile feedback confirmed stability. All mobility protocols appear fully operational.